- High-Performance Doors
-
- Applications
-
-
-
- Clean Room
Stainless steel or composite materials help maintain clean rooms.
-
-
- Coolers
Quick opening speeds & tight seals for temperature control.
-
-
- Parking
Improve security & traffic flow and enhance architectural style.
-
-
- Hurricane Zone
Withstand winds up to 175 mph and comply with the Florida Building Code.
-
-
-
-
- USDA / FDA / cGMP
Increase productivity & address stringent USDA, FDA & cGMP requirements.
-
-
- Freezers
High-speed & perimeter seals minimize the air exchange between areas.
-
-
- Security
High speed & durability ensure secure access.
-
-
- Ventilation
Perforated or screen door panels allow improved air circulation.
-
-
-
-
- Fire Station Emergency Response
When time is of the essence, high speed and reliability are crucial.
-
-
- Warehousing
Fast cycle times and secure seals keep environments separated.
-
-
- Loading Dock
Rugged design & secure seal for oversized openings.
-
-
- Large Openings
Break-away functionality with rugged design seals oversized openings.
-
-
-
-
- Heavy Equipment
Withstands challenges of heavy equipment and fleet truck/car wash environments.
-
-
- Self-Storage
Fast opening speeds and reliable, durable construction keep facilities secure and protected.
-
-
- Industries
-
-
-
- Automotive Dealerships
Reduce energy costs, increase productivity and comfort and enhance customer perception.
-
-
- Cold Storage & Processing
Increase productivity and operational efficiency while reducing energy and maintenance costs.
-
-
- Parking
We offer solutions for Apartment / Condo & Loft, Standalone Parking Facilities and Office Buildings
-
-
-
-
- Food & Beverage
Doors specifically engineered for USDA/FDA and cGMP environments, and assured compliance for uncompromising performance.
-
-
- Mfg/Dist/Warehousing
A complete product line allows facilities to increase efficiency and safety and reduce maintenance and energy costs.
-
-
- Government
Ensure effective security and environmental controls are maintained for critical government operations.
-
-
-
-
- Transit
Keep operations running smoothly and efficient while reducing energy and maintenance costs.
-
-
- Pharma, Nutraceutical & Biotech
Doors that offer quick, secure access, environmental control and reliability for life science facilities.
-
-
- Support Resources
- Parts
- Contact Us
- Blog/News
- Why Rytec
- Sales Rep Locator
- Careers
- Dealers
- Architectural Resources
2026 Best Fly Controller Drone for Global Buyers
Choosing the 2026 Best Fly Controller Drone requires more than comparing camera pixels or advertised flight time. Global buyers need dependable control, clear feedback, and practical support after purchase. A drone may look impressive in a showroom, yet feel unstable in coastal wind or crowded urban spaces. That difference matters.
Colin Guinn, a longtime drone industry executive, once stated, “The drone is not the product. The data is the product.” His observation remains relevant. A reliable Fly Controller Drone should capture useful footage while maintaining responsive controls, stable transmission, and predictable battery performance. Test results should be read carefully. Manufacturer claims often reflect ideal conditions, not cold mornings, strong gusts, or repeated takeoffs.
This guide examines controller ergonomics, signal range, obstacle sensing, return-to-home accuracy, app usability, and repair access. It also considers regional requirements, because flight rules, registration duties, and restricted zones differ worldwide. Buyers should check official local guidance before operating any aircraft. Safety is not an optional feature.
Small details reveal quality. Buttons should remain usable with gloves. The screen should stay readable under harsh sunlight. Firmware updates should be transparent. Customer service should answer clearly.
No model is perfect.
A few weaknesses may appear. Some premium drones remain expensive, and compact models can sacrifice wind resistance. Still, careful comparison can prevent costly disappointment. The strongest choice is not always the fastest or most advanced aircraft. It is the one that matches the pilot’s experience, location, work demands, and realistic flying habits.
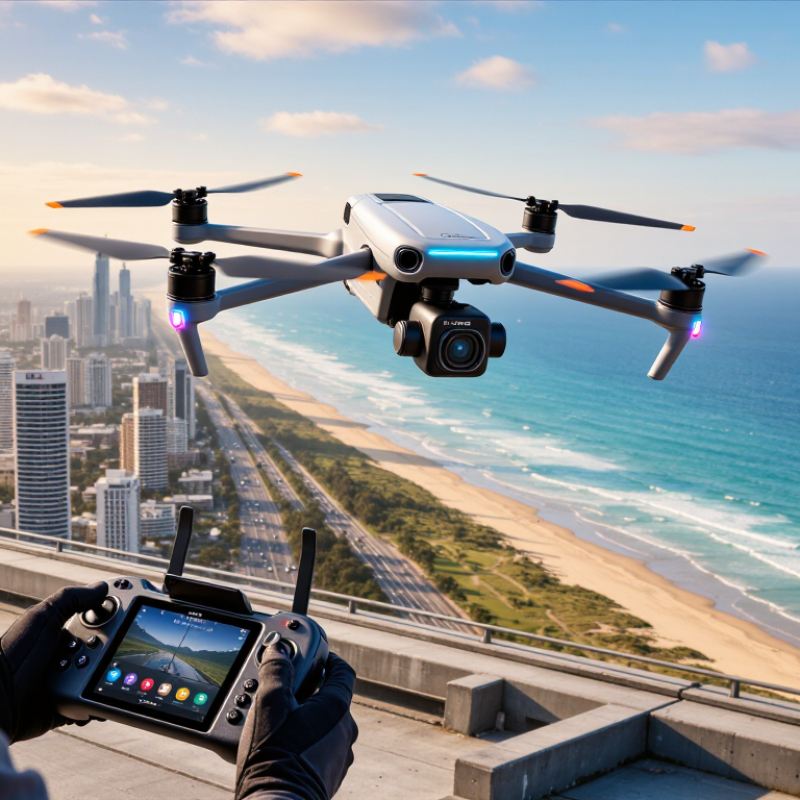
Table of Contents [Hide]
What Defines the Best Fly Controller Drone in 2026
What Defines the Best Fly Controller Drone in 2026
The best fly controller drone in 2026 is not defined by maximum speed. It is defined by predictable control, stable positioning, and safe recovery when conditions change. A responsive flight controller should combine satellite navigation, inertial sensors, obstacle awareness, and dependable signal management. These features matter during coastal gusts, narrow urban spaces, and low-light landings.
Grand View Research estimated the global commercial drone market at about 30.6 billion dollars in 2023. Its report also projects strong growth through 2030. This expansion increases expectations for accurate automation and reliable operator control. However, market estimates differ between research firms. Buyers should not treat one forecast as absolute truth. Field testing remains more valuable than impressive packaging.
Tips: Check control latency, return-to-home accuracy, wind resistance, and firmware support. Test the drone at low altitude first. A controller that feels smooth indoors may react differently near buildings. Battery endurance should include reserve power, not only laboratory flight time. I also prefer physical controls for emergency adjustments, although screen-based systems can be easier for beginners. Review local aviation requirements before flying, and record a short test flight for later comparison.